One Robotics Supply Group

HOME / CAPABILITIES / PARTS & COMPONENTS / Robot Grippers

Robot Grippers

Robot grippers are end effectors designed to grasp, hold, move and release objects during automated tasks. From simple repetitive handling to adaptive picking, the correct gripper can determine whether a robotic system handles its target parts reliably.

One Robotics Supply Group is developing commercial capabilities to help organizations evaluate gripping requirements, component options, sourcing and integration for commercial robotic deployments.

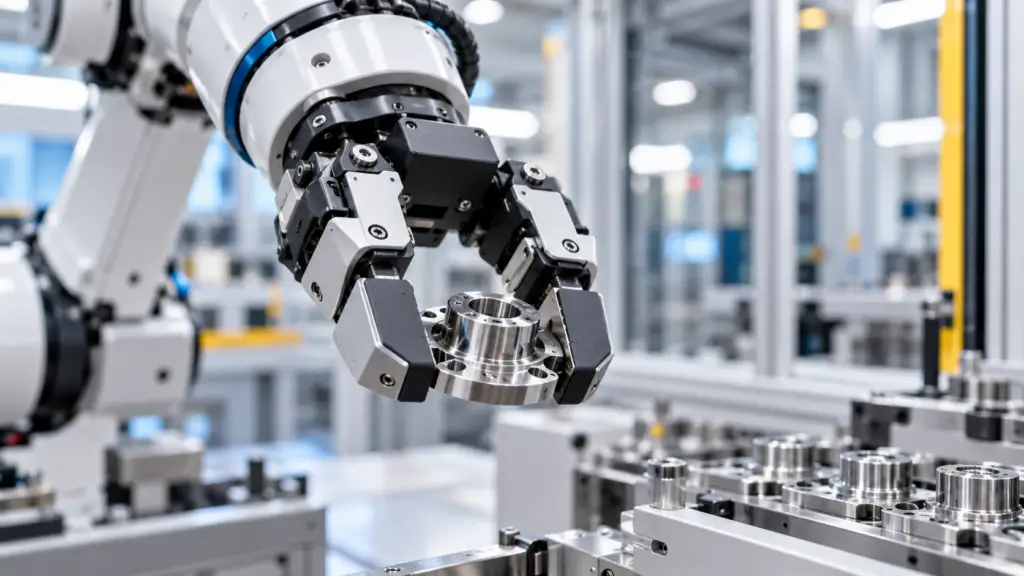
Industrial robot gripper handling a precision component

UNDERSTANDING ROBOT GRIPPERS

What Are Robot Grippers?

A robot gripper is a tool mounted at the end of a robotic arm or manipulator to make physical contact with an object. Grippers can use fingers, jaws, suction, magnetic force or other mechanisms depending on the material, shape and handling requirement.

The best gripper is task-dependent. A rigid part with predictable geometry may work well with a simple parallel-jaw design, while variable consumer products, delicate items or mixed-object picking may require adaptive fingers, compliant contact surfaces or sensing. Selection should begin with the object and process rather than the gripper specification alone.

GRIPPER TECHNOLOGIES

Common Robot Gripper Types

Parallel-jaw grippers

Two opposing fingers move toward or away from each other to hold a part. They are widely used where object geometry is consistent and repeatability is important.

Adaptive grippers

Adaptive fingers can conform to a wider range of shapes and may reduce the need for dedicated tooling across variable objects.

Electric grippers

Electric actuation can provide programmable position, speed and force with convenient integration into many robotic platforms.

Pneumatic grippers

Pneumatic grippers use compressed air for fast, repeatable opening and closing and remain common in industrial automation.

Vacuum gripping

Vacuum cups can handle sheets, cartons and other surfaces where suction provides a reliable contact method.

Specialized gripping

Magnetic, soft robotic and application-specific end effectors may be appropriate where standard finger or vacuum approaches do not fit the task.

PRACTICAL EVALUATION

Key Robot Gripper Selection Factors

Object geometry

Part size, shape, orientation and available contact surfaces strongly influence the gripping approach.

Payload and grip force

The gripper must securely hold the object through acceleration and movement without damaging the item or exceeding robot payload limits.

Material and surface

Fragile, porous, flexible, oily, smooth or irregular surfaces can require different contact materials and gripping methods.

Stroke and opening range

The gripper must accommodate the expected object size variation while maintaining usable force and positioning.

Cycle time

High-throughput automation may prioritize fast actuation and short settling time.

Environment and maintenance

Dust, washdown, temperature, contamination and wear can affect the choice of mechanism, seals and replaceable contact components.

ROBOTICS APPLICATIONS

Where Robot Grippers Fit in Robotics

Robot grippers are used in picking and sorting, machine tending, packaging, palletizing, assembly support, laboratory automation, material handling and other tasks where a robot must physically control an object. The end effector often becomes the final point of contact between the robotic system and the product, making gripper selection central to process reliability.

SOURCING & PROCUREMENT

Sourcing and Procurement for Robot Grippers

Commercial gripper sourcing should account for more than purchase price. Teams may need to compare finger options, spare parts, mounting patterns, communication interfaces, controller requirements, pneumatic infrastructure, lead times and the ease of switching between products. As its capabilities develop, ORSG welcomes discussions about how it may help organizations structure these requirements and evaluate gripper options within a broader procurement and deployment plan.

Discuss Your Requirements

FROM COMPONENT TO SYSTEM

Integration and Lifecycle Considerations

Gripper integration can involve mechanical adapters, electrical or pneumatic connections, I/O, robot programming, force limits, object detection and safety behavior. For vision-guided picking, the gripper also needs to work with perception and motion planning. Testing should use representative objects and realistic cycle conditions before the end effector is treated as production-ready.

WHO THIS IS FOR

Who This Page Is For

This page is intended for robot manufacturers, OEMs, systems integrators, engineering organizations, industrial automation teams, procurement professionals and companies evaluating or deploying advanced robotic systems.

FREQUENTLY ASKED QUESTIONS

Frequently Asked Questions About Robot Grippers

What is a robot gripper?

A robot gripper is an end effector that allows a robot to grasp, hold, move and release objects during an automated task.

What are the main types of robot grippers?

Common categories include parallel-jaw, adaptive, electric, pneumatic, vacuum and specialized gripping systems.

How do I choose a robot gripper?

Start with the object, required cycle, payload, surface condition, size variation and environment, then evaluate actuation, grip force, stroke and integration requirements.

What is the difference between a robotic hand and a gripper?

A gripper is generally optimized for a defined range of handling tasks, while a robotic hand usually provides more articulated fingers and degrees of freedom for dexterous manipulation.

Can a robot gripper include sensors?

Yes. Depending on the design, grippers may use position, force, contact or object-detection sensing to improve control and confirm successful gripping.

Can ORSG support robot gripper sourcing?

As its capabilities develop, ORSG welcomes discussions about how it may support organizations evaluating robotics components by helping define requirements, compare commercial options and connect end-effector selection with system integration and deployment.
START A CONVERSATION

Looking for the Right Robotic Gripping System?

Share your technical, sourcing and deployment requirements. One Robotics Supply Group welcomes conversations as we develop commercial relationships and capabilities across the robotics ecosystem.