What is a robot joint?
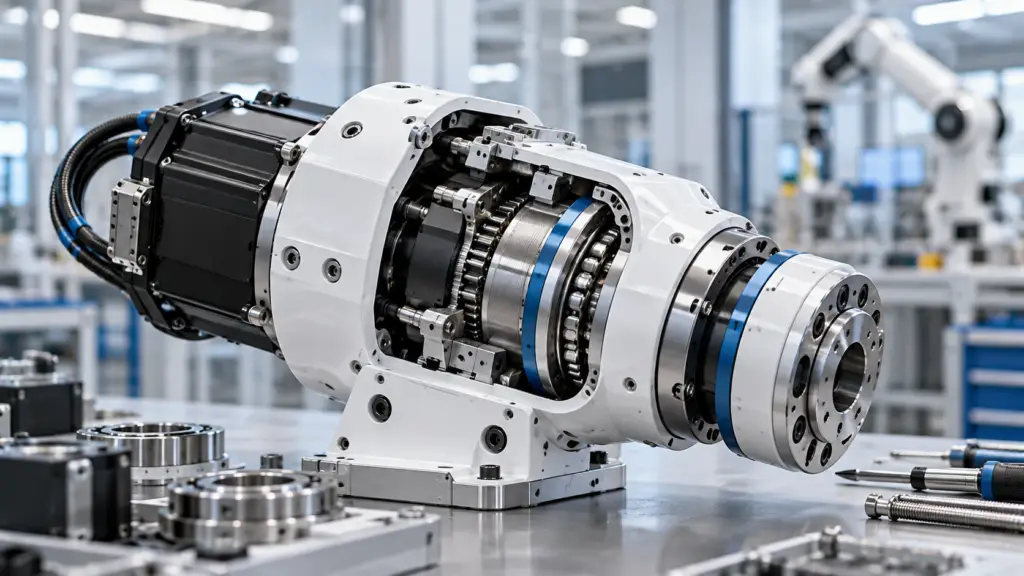
A robot joint is the connection between robot links that permits controlled motion. Depending on the design, it may provide rotation, linear movement or compliant motion while carrying structural and dynamic loads.
What is an integrated robot joint?
An integrated robot joint combines several functions such as a motor, gearbox, bearings, encoder, sensors and control electronics in one compact module.
How are robot joints different from actuators?
An actuator produces motion or force. A robot joint is the larger mechanical or electromechanical assembly where that actuation is translated into controlled movement between robot links.
What matters when selecting a robot joint?
Common considerations include torque, speed, range of motion, backlash, stiffness, size, mass, thermal performance, sensing, control compatibility and lifecycle support.
Why are compact joints important in humanoid robotics?
Humanoid robots distribute many joints throughout the body. Lower mass and higher torque density can reduce the load carried by adjacent joints and improve overall mobility and efficiency.
Can ORSG support robot joint sourcing?
As its capabilities develop, ORSG welcomes discussions about how it may support organizations evaluating robotics parts and components by helping define sourcing requirements, assess commercial options and connect component decisions with integration and deployment needs.